01
Highlights
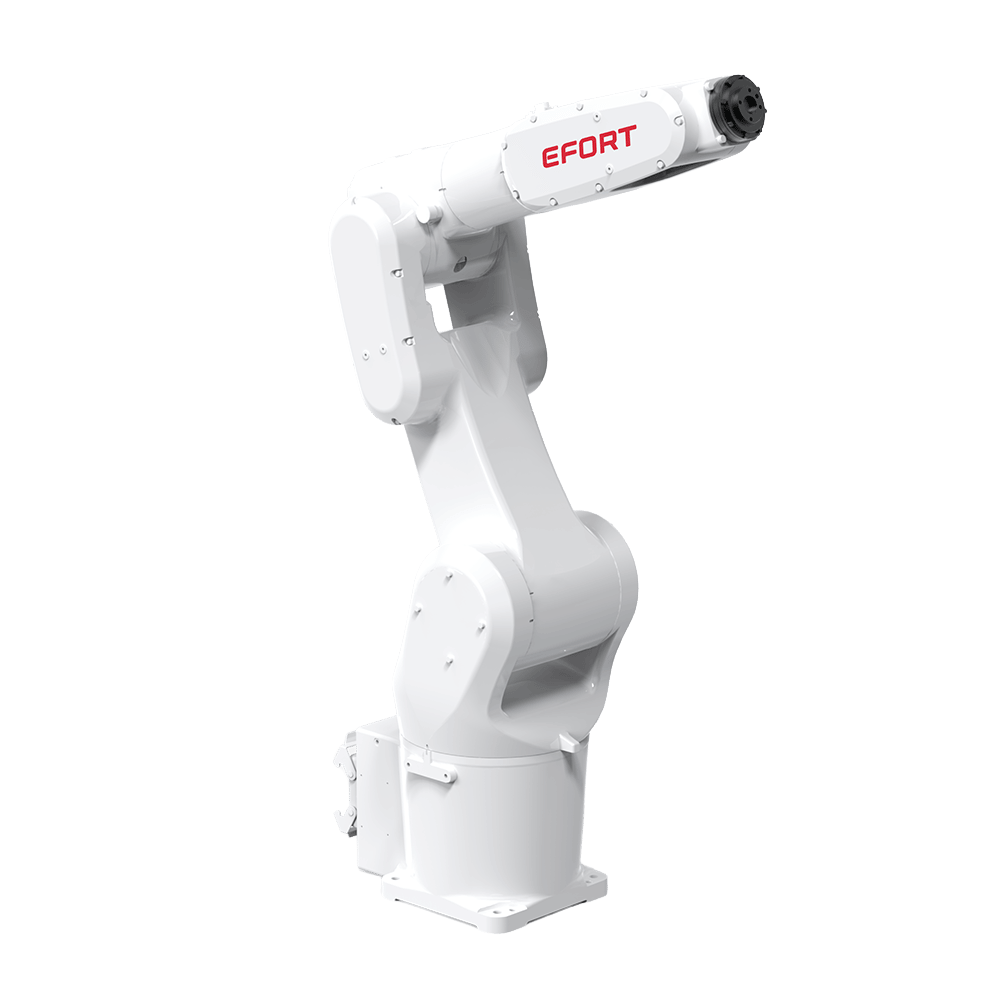
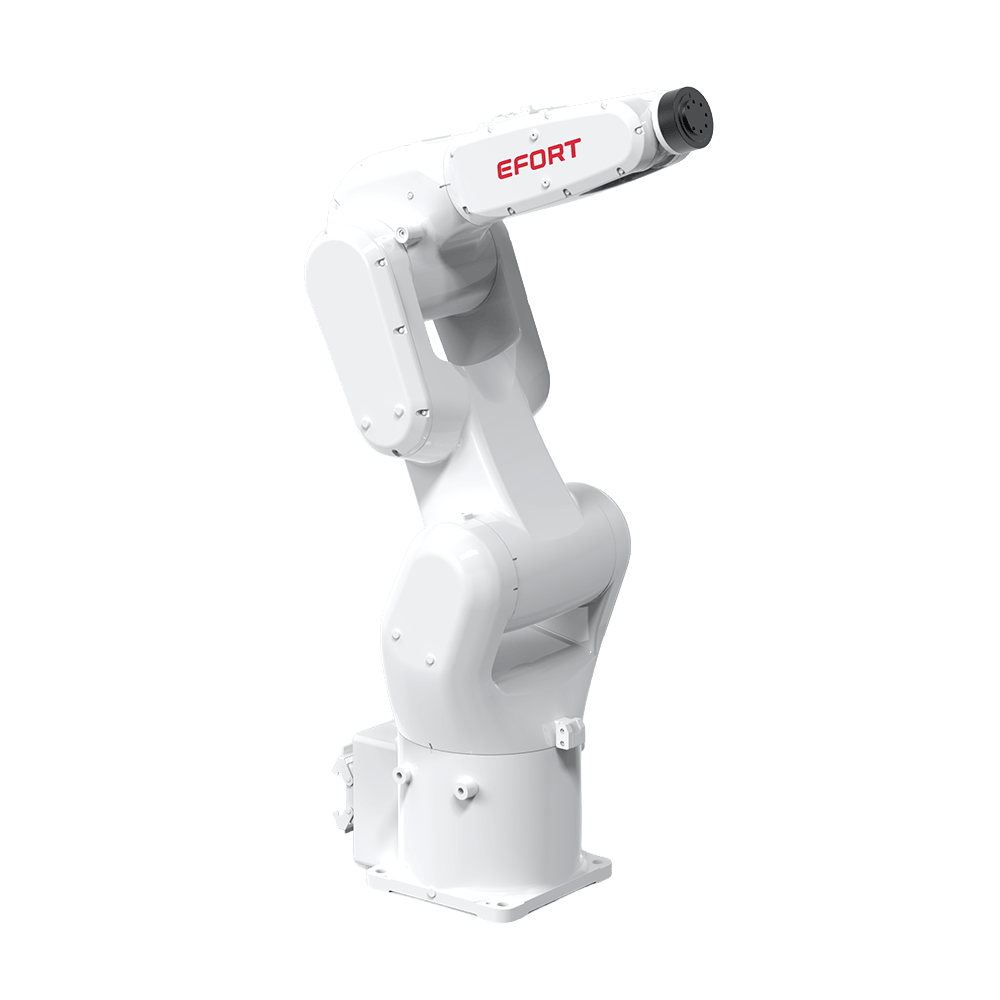
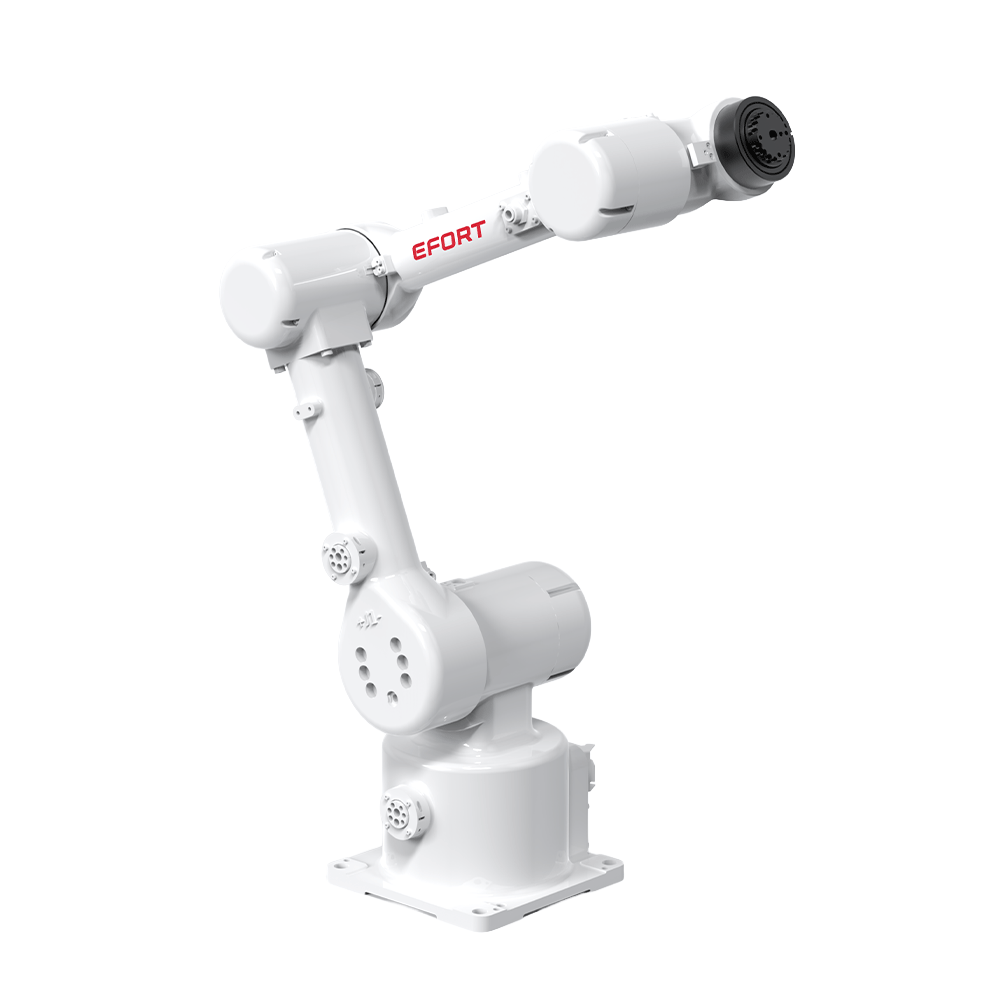
High inertia design of the robot wrist greatly improves the stability in high-speed movement. It plus advanced kinematic algorithms to helps the takt improved by 25%;
Thanks to industry-leading joint seal construction and oil leakage prevention design, the robot can help customers easily face various scenarios with high cleanliness requirements;
The 4th rotation axis offer more flexibility to variey kinds of robot mounting position.
02
Industries
It can be used in handling operations.
02
Industries
Suitable for PCB, electronic manufacturing, plastic, metal parts, and other industries.
04
Specification
| Model | ER10-4-900 | |
|---|---|---|
| Type | Articulated | |
| Controlled axes | 6 Axes | |
| Max. payload on wrist | 10 kg | |
| Repeatability | +/- 0.05 mm | |
| Robot weight | 35 kg | |
| Reach | 860 mm | |
| Robot IP grade | IP54 | |
| Cabinet IP grade | IP20 | |
| Drive mode | AC servo drive | |
| Installation | Upside-down | |
| Installation enviroment | ||
|---|---|---|
| Installation enviroment | Ambient temperature | 0~45 ℃ |
| Ambient humidity | RH≤80% (No dew nor frost allowed) | |
| Vibration acceleration | 4.9 m/s² (<0.5 G) | |
| Allowable load moment at wrist | ||
| Allowable load moment at wrist | J3 | 20 N•m |
| J4 | 8 N•m | |
| Allowable load inertia at wrist | ||
| Allowable load inertia at wrist | J3 | 1.5 kg•m² |
| J4 | 0.8 kg•m² | |
| Maximum speed | ||
| Maximum speed | J1 | 300° / sec |
| J2 | 320° / sec | |
| J3 | 380° / sec | |
| J4 | 600°/ sec | |
| Motion range | ||
| Motion range | J1 | +/- 130° |
| J2 | + 250° / - 69° | |
| J3 | +/- 130° | |
| J4 | +/- 360° | |
Contact us
Contact us
Efort robots offer an innovative approach to key industrial applications.